Introduction
Algorithms are crucial in computer science because they give a systematic way of solving a problem efficiently. As software is written, it is common for a programmer to have to make choices on the way information should be processed, resources allocated, activities organised, or among a variety of solutions for a problem. There are some problems that may be solved by simple instructions, and others that are more complex and involve more sophisticated problem solving skills. Greedy algorithms and dynamic programming are two of the most important methods that can be used for solving optimization problems. Both strategies help to divide a problem into manageable parts, but they differ in the way they make the decisions and determine the optimal outcome. Programmers can use this knowledge to choose appropriate algorithms and optimize program performance, thereby avoiding repetitive calculations. Greedy algorithms work on making the optimum choice at every step but dynamic programming computes the solutions for related subproblems and uses them to build an optimum solution.
What are Greedy Algorithms?
A greedy strategy is the type of approach that is usually used in solving a problem in which at each step, the best choice among the choices currently available is made with no further thought to previous decisions. The principle is that if we always choose the locally best solution, then we will eventually get a good solution to the overall problem. A person might select the activity that ends first, for instance, when choosing activities for a busy day, so as to have more time available for other activities. A computer program may proceed in a similar manner, it can conduct an examination of the options presented and pick the one that satisfies a given rule, and it can repeat this until it finds a solution. Greedy algorithms are widely used due to their simplicity and ease of understanding, implementation and execution. But there is a significant drawback to their simplicity: selecting the most advantageous short-term solution is not always the most effective long-term solution.
Two key mathematical properties of a problem are the greedy-choice property and optimal substructure, which make the greedy algorithm a particularly useful option. The locally best choice is the globally optimal solution is the greedy-choice property. Optimal substructure: If there is an optimal solution to a large problem, it can be built from optimal solutions to smaller subproblems. The two properties are used when proving the correctness of a greedy algorithm. An algorithm for solving an activity-selection problem that picks the earliest finishing activity can be proved to choose the most compatible activities, for instance. Conversely, if the goal of the knapsack problem is to select the most valuable item in the knapsack, the program might not be able to make a better selection of items. So, the programmer has to decide whether to use a greedy approach and not take it for granted that it is appropriate just because it looks reasonable.
How Greedy Algorithms Operate.
The basic steps of greedy algorithms are simple to follow. The first step in the program is to identify the possible options and to select the rule for decision-making. It then looks at the options and chooses the one that looks the most useful based on that criteria. The program then updates the current state, discards any inappropriate choices and restarts the process until the problem is resolved or there are no options left available. The selection rule may be the smallest value, the largest benefit, the earliest finishing time or the shortest available distance depending on the problem. The procedure may look the same in different applications, but it is important that the selection rule is developed to fit the problem at hand. The principle of understanding the problem more than just applying a familiar technique is illustrated by a good algorithm for scheduling activities that is not suitable for allocation of indivisible resources.
Suppose there is a delivery company that has to choose a number of jobs to be delivered in one delivery vehicle. A job will have an initial time and an end time and the vehicle cannot work on two jobs at once. The company would like to schedule jobs to complete as many jobs as possible without any overlapping schedules. The jobs can be sorted by finishing times and the first job to become finished can be selected. It then looks at the remaining jobs and takes on any job that comes after the job it is selected. The algorithm repeatedly selects the activity that fits in the earliest available time until it is completed, to maximize the slack time for subsequent activities. This approach gives the maximum possible solution for solving the standard activity-selection problem where the goal is to get the maximum number of mutually exclusive activities. It is successful because of its property that the earliest choice is safe – not because the earliest choice is universally good.
What is Dynamic Programming?
Dynamic programming is a method for designing an algorithm that breaks down a problem into smaller, simpler subproblems and stores the results of these subproblems to avoid redundant calculations. A dynamic programming algorithm takes the alternatives under consideration, and calculates the contribution of their outcomes to the outcome of the overall solution, rather than accepting the first attractive alternative on the spot. This is particularly helpful if the same subproblems are computed more than once in the calculation. A program without dynamic programming may compute the same answer numerous times, thereby consuming a lot of processor time. The program can store the answers that have been calculated earlier so that, if needed, it can reuse these answers. The main applications of dynamic programming are resource allocation, minimizing costs and costs of sequences, and choosing items when constraints exist. Its sole benefit is that it can compare alternatives one by one and find the optimum solution to a problem when the problem was formulated correctly and the algorithm considers all the states that the problem needs.
Optimal substructure and overlapping subproblems are two important concepts in dynamic programming. In problems where the answer to a smaller problem needs to be calculated more than once for different subproblems in the overall process, the smaller problems are called as subproblems, and the resulting answers are stored in a table to be reused, this is referred as overlapping subproblems. An optimal substructure is a problem that can be broken down into smaller subproblems whose solutions can be combined to form the solution to the larger problem. These properties can be exploited in dynamic programming to structure the calculations and to prevent redundant work. Two possible implementation approaches are: Memoization and Tabulation. Memoization is a top-down approach that typically involves storing each result as soon as it is computed, using a recursive function. Tabulation: A bottom up technique, solving smaller problems first, and storing the results in a table until the answer to the original problem is available. Both of the methods can improve the efficiency, but the needed memory and the way they are executed rely on the problem considered.
How Dynamic Programming Works
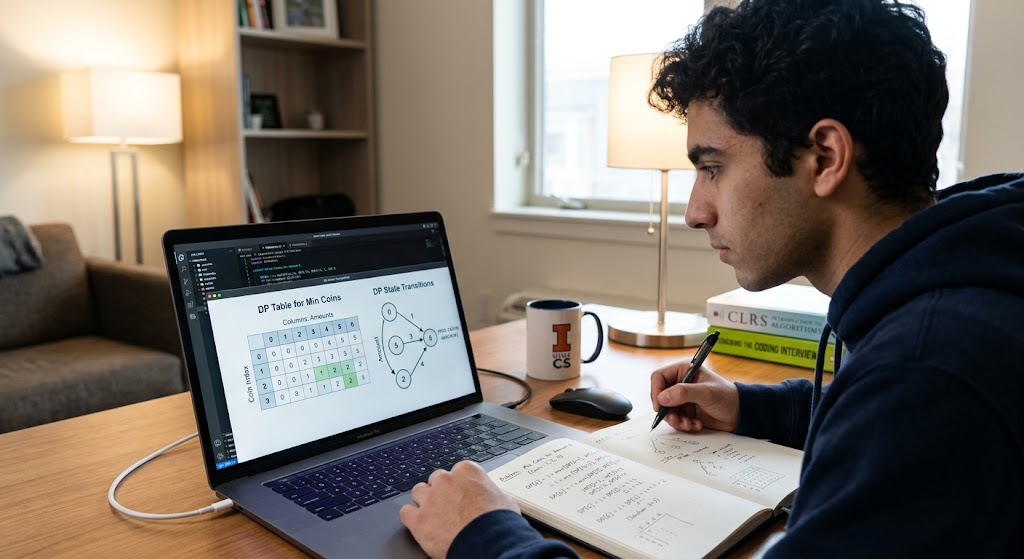
In order to understand dynamic programming, let’s take an example of the program that calculates the minimum number of coins needed to make a specific amount of money. The program is given an array of denominations of coins and a sum, and asks for how many coins will be required to be able to make that sum using the given denominations. The first step in a dynamic programming solution is a simple base case – if the target value is zero, then no coins are needed. It then works out how many coins it takes for a progressively larger amount, and uses the results it has calculated to consider the choices of coins it has available. For every amount it checks if a certain coin can actually make a better difference if it is added to a smaller amount. It compares the valid alternatives and writes the minimum number of coins needed. The process repeats itself until the desired sum is calculated; as a result, the program does not need to solve the same smaller problems again and again.
The general concept of coin-change problems is quite important for understanding why some coin-change problems are better solved with dynamic programming than with a greedy algorithm. Assume that the denominations of coins were 1, 3, and 4 and the amount 6. A greedy strategy which first takes the largest coin available chooses a 4 first leaving 2. It then chooses two coins of value 1, resulting in the selection of three coins. The best answer however, is to have 2 coins that are each 3. A better answer could be found by using a dynamic programming algorithm which will consider the possibilities of each amount instead of the maximum coin at each stage. In this example, it is shown that a locally attractive solution can yield a worse global solution. It also demonstrates the need for programmers to have a clear idea of a problem’s structure before deciding whether a greedy algorithm is adequate.
Differences between Greedy Algorithms and Dynamic Programming.
The primary difference between a greedy algorithm and a dynamic programming algorithm is that the former’s solution choices are based on local optimization considerations and the latter’s solution choices are based on the global optimization considerations. A greedy algorithm takes a “local” optimum and typically does not consider all the options. Dynamic programming considers smaller subproblems to assess the relevant alternatives and uses their results to determine the best overall solution. Greedy algorithms may be faster and less memory intensive because it is possible they only need to keep track of the current solution. Often dynamic programming needs extra storage to store the results of computations, but this can save a great deal of re-computation. The right solution has got to do with the mathematical nature of the problem, the size of the input and the resources at hand. Neither technique is necessarily best in all cases, but the goal is to use a minimal algorithm, which will always achieve the desired result.
| Feature | Greedy Algorithms | Dynamic Programming |
| Decision-making | Chooses the most appropriate immediate option based on a set criterion. | Solves relevant alternatives by solving smaller subproblems. |
| Previous decisions | Typically makes decisions without reviewing them. | Uses previously computed results of subproblems to find an optimum solution. |
| Main requirements | Needs greedy choice property and appropriate optimal substructure. | Typically employs overlapping subproblems and optimal substructure. |
| Memory usage | Typically low due to limited information stored. | Frequently higher due to the need for intermediate results to be stored. |
| Implementation | Easy to implement when using a correct “greedy” rule. | May need to use recurrence relations, tables and/or memoization. |
| Performance | Can be very efficient since many alternatives are not explored. | Decreases according to the number of states and amount of work needed for each state. |
| Correctness | Can give suboptimal solutions if the greedy rule is not appropriate. | Can give the best possible answer if the recurrence and the evaluation of the state is correct. |
| Typical examples | Activity selection and fractional knapsack, and some shortest-path problems. | General coin change, 0/1 knapsack and sequence optimization. |
One of the important differences with dynamic programming is that it is not always necessary to consider all possible complete solutions separately. Rather, it structures the calculations in such a way that each of the subproblems can be used to generate multiple larger solutions. This is better than a simple exhaustive search in many cases. In the same way, a “greedy” algorithm is not just a random shortcut: a greedy algorithm is one which has a specific rule that can be mathematically proven to be correct. For instance, both methods can benefit from optimal substructure, but with the further requirement that there are safe choices in the greedy algorithm that can be part of an optimal solution. This is important to understand because a program may execute fast and yet be wrong. The selection of algorithms should then take into account the efficiency as well as the proof of correctness.
Example 1: The Coin-Change Problem
The coin change problem illustrates how to make quick decisions, versus how to systematically compare options. Its basic version is to find the minimum number of coins required to make a sum of money using a specific set of coins. A greedy approach usually proceeds by selecting the highest denomination coin that does not exceed the remaining amount and does so repeatedly until all the coins are used. This method works for some sets of denominations, such as common ones like most of our everyday money, but not all sets of denominations. The greedy algorithm selects the highest value coin that fits into the desired sum, then uses the next highest value coin and so on until the desired sum is reached. In the case of a desired amount of 6 units, with coins of 1, 3 and 4 units, the greedy algorithm would select the 4 unit coin first, followed by the 1 unit coin twice. The result requires three coins, while picking two coins of value 3 can provide the same result with just two coins.
This is a problem that can be solved using Dynamic Programming, which stores the minimum number of coins needed to make each amount up to the target amount and then uses that information to calculate the minimum number needed to make the target amount. Suppose that dp[x] is the smallest number of coins required to make up the amount x.Let dp[x] denote the minimum number of coins to make up the amount x. The base case of dp[0] = 0 makes sense because zero coins are needed to make the sum of zero. For every positive value, the algorithm looks at all the possible coins that can be used that do not exceed the given value and computes the cost of using the coin and the optimal solution for the remaining amount. The recurrence is to calculate dp[x] as 1 + the minimum value of dp[x – c] for all coin denominations c that can be used for x. If it is impossible to form a combination, the algorithm notes that the number cannot be made. This method runs in O(A×k) time and O(A) space, in the standard bottom-up solution. Its system comparisons ensure the lowest number of coins used, if the recurrence is accurate.
Example 2: The Activity-Selection Problem
Activity selection problem: Given a set of ‘activities’ with start and end times, what is the largest number of activities that can be selected such that they do not overlap. It is used in real life contexts like timetabling lessons in the classroom, arranging meetings, or scheduling jobs to a shared resource. Only one person or resource can be involved in one activity at a time, thus the activities chosen should be compatible. It might appear that the shortest activity (or the one starting at the earliest time) should be chosen, but neither of these rules is assured of maximizing the number of activities chosen. The common greedy approach, however, is to choose the activity that ends first, since that will result in the longest time to date until the end of the remaining activities. This option may be demonstrated to be safe and the algorithm can easily develop an optimal schedule.
Suppose a classroom has activities scheduled from 9:00 to 10:00, 9:30 to 10:30, 10:00 to 11:00, and 11:00 to 12:00. The greedy algorithm is going to choose the activity that ends at 10:00 first. It then moves on to the remaining activities and picks out the one which starts at 10:00 and ends at 11:00, next the one that starts at 11:00 and ends at 12:00. If the activities meet at an endpoint, then the resulting schedule has three activities (assuming it is compatible). If you pick the activity starting at 9:30, then the algorithm will not be able to pick the activity starting at 9:00 to 10:00, and will also end later than the first activity. This is an example of the benefits of the finishing-time rule. We can sort the activities by finishing time in O(n log n) time and perform the scan on the sorted activities in O(n) time, which makes the greedy solution simple and efficient to implement in O(n log n).
Example 3: Shortest-Path Calculations
Shortest-path problems are those whose purpose is to determine the minimum total distance or cost needed to reach a given location (vertex) in a graph from a starting point. The vertices can be cities, computer networks, or any other sorts of connected entities, and the edges are the available routes between the cities. Weights can be assigned to each edge, which can measure distance, travel cost, or some other measure. Dijkstra’s algorithm is a popular solution for this problem, which is based on a greedy approach using only non-negative edge weights. The algorithm takes the smallest known distance to an unvisited vertex, always from a vertex that was previously visited, and selects that vertex to be the next vertex to visit. Then it looks at all of the outgoing edges of that vertex and changes the estimate of the distance to the neighboring vertices if a shorter path is found. Under the conditions it requires, Dijkstra’s algorithm is able to efficiently calculate the length of shortest paths by repeatedly picking the nearest unsettled vertex.
The key restriction of Dijkstra’s algorithm is that all of the edge weights must be positive. In this case, if the algorithm picks the smallest tentative distance vertex that hasn’t been visited, there will be no other path through any other unsettled vertex that can result in a smaller tentative distance to that vertex. This property allows making the greedy choice without risk. The graph above is not allowed, though, because the negative weight on the edges would disallow the argument since visiting another vertex might make the total cost less than the minimum distance traveled. If the edge is negative, then algorithms like Bellman-Ford might be more suitable, but as long as their assumptions are met and negative cycles are dealt with appropriately. Some shortest-path algorithms are also based on dynamic programming, such as the ones that use increasingly large sets of allowed intermediate vertices to calculate the paths. Hence, the choice of algorithm is not just a matter of the name of the problem, but also of the structure and weight constraints of the graph.
Example 4: Knapsack Problem
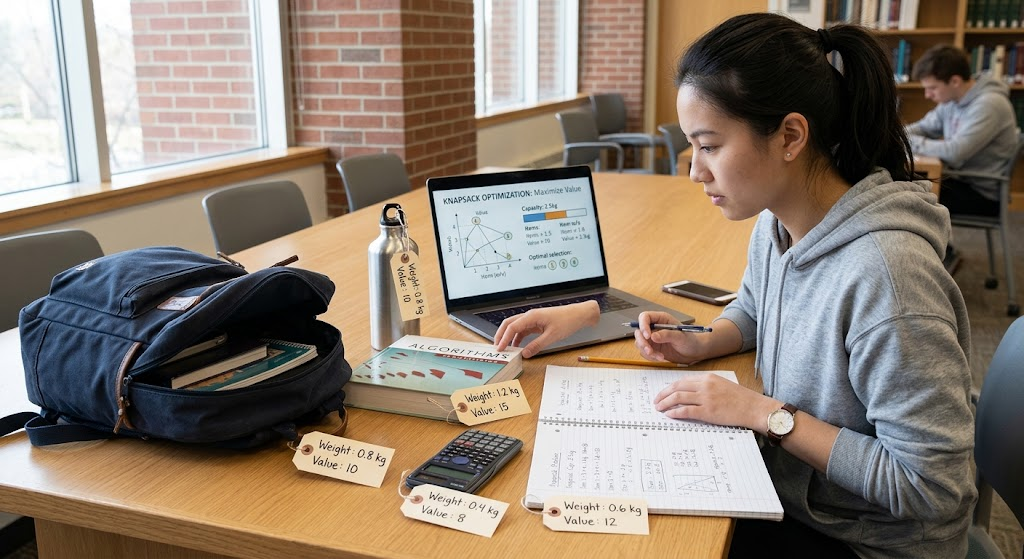
The knapsack problem is a scenario where a particular number of items are to be selected from a set so that the sum of the values of the items placed in a knapsack is maximized, while the sum of the weights of the items placed in a knapsack is constrained to be less than a given value. There are two parameters to every item: its weight and its value, and the goal of the algorithm is to select some subset of these items. There are two important variations of this problem: fractional knapsack and 0/1 knapsack. In a fractional knapsack, the items can be split and if the remaining space inside the knapsack is not enough for the entire item, a portion of the item will be taken. For 0/1 knapsack, each item is either taken or left out of the knapsack. While these differences seem to be similar, they do have differences that impact which algorithmic approach will lead to an optimal solution. The fractional version can be solved by a greedy approach of value per unit weight; the general 0/1 version can be solved by dynamic programming if the capacity is limited.
Suppose there is a bag that can hold a total of 10 kg, containing three items with the values of 30 units, 25 units and 24 units and the weights of 6 kg, 5 kg and 4 kg respectively. The value to weight ratios are 5,5, and 6 for the fractional version. A greedy algorithm takes the third object first as it provides the highest value per kilogram, and then packs the rest of the space with an appropriate proportion of the other object. It is an ideal strategy for fractional knapsack as the maximum value item will be the first to be taken, ensuring that the capacity is utilized as effectively as possible. In the case of 0/1 however, the program is not able to divide items, and if an item is selected, another item may not be selected if the combination is more valuable. Dynamic programming is suitable as it calculates the best results that can be achieved by including or excluding each item.
How Dynamic Programming can be used to solve the 0/1 Knapsack Problem.
The 0/1 knapsack problem is solved using dynamic programming, by iterating through each item and keeping a record of the best value possible for each possible weight. Define dp[i][w] as the maximum value that can be achieved from the first i items when the maximum capacity is w.Define the maximum value that can be achieved using the first i items with maximum capacity w as dp[i][w]. The algorithm will look at two options for each item: whether or not to include it in the subproblem, and if it can be included, whether it’ll fit in the available capacity. Removing an item gives the maximum value based on the previous item(s). Adding it to the set will increase the value of the best total value set with the remaining capacity and the previous set. The algorithm selects the one which yields a greater value. It calculates these results for each item and capacity and it constructs a table with the optimal answer to the full problem. The standard implementation requires O(nW) time and space, with n being the number of items and W being the capacity of the object, measured in integer units.
The nice thing about this is that it will include combinations that the greedy algorithm might not. When items are not divisible, the best choice will not necessarily be the one with the greatest value, the lightest weight or greatest value-to-weight ratio. For instance, if one item has a high value, it can take up much space that two other items, which have a larger value, cannot fit in. Dynamic programming explores these competing possibilities by computing them with its recurrence relation, not by assuming one ranking rule is always true. The downside of this is that the running time is limited to the numerical capacity and therefore it is costly if W is very large. This is called pseudo-polynomial time as the algorithm is polynomial in the numerical value of the capacity, but not necessarily on the number of bits needed to represent the capacity. If it is a large capacity then alternative algorithms or approximation methods may be required.
When to use a Greedy Algorithm
For problems with a clear selection rule which is demonstrated to maintain the potential for an optimum solution, a greedy algorithm works well. It is particularly convenient when each decision is made without relying on future decisions which are unknown, or if a mathematical property ensures that the locally optimal decision is relatively safe. A typical activity selection problem is picking the first one to finish activity that will allow as many as possible later activities to be chosen. Another example is fractional knapsack, where the selection of available item fractions that maximizes the return from the available capacity is made. Greedy algorithms are also used in finding minimum spanning tree algorithms like Kruskal’s and Prim’s algorithm which employs certain selection criteria to build a minimum-cost spanning tree. They are efficient to use for large input, as long as they conform to their correctness conditions.
Before using a greedy solution, the programmer should first consider how one solution is better than the other and if it is better, whether or not it is possible to choose it so that the globally optimal solution is not produced. One of the more common methods of proving correctness is an exchange argument. This means to give a comparison of an optimal solution and a solution that starts with the greedy choice and show that the original solution can be changed so that it contains the greedy choice without it getting any worse. If this is true, then the algorithm can go ahead and solve the remaining smaller problem since the greedy choice is always “safe”. It is also helpful to test the algorithm on carefully selected examples, which may include examples that demonstrate the shortcomings of the selection rule. But passing the tests doesn’t imply correctness for all possible inputs. A greedy algorithm is to be optimized because it makes a decision based on the mathematical structure of the problem, not just because it works on a few examples that are familiar.
When to use Dynamic Programming
Dynamic programming is suitable when a problem has overlapping subproblems and/or has optimal substructure, particularly when a suboptimal decision locally can lead to a suboptimal decision overall. It can be useful in optimization problems involving comparing different combinations (e.g., 0/1 knapsack, minimum coin change – arbitrary denominations, some sequence comparison – etc.). Dynamic programming: computes smaller results first and then reuses them in computing the larger results, rather than accepting one solution without doing any extra work. It’s useful in the case where there is no easy greedy rule that can be proved correct. For instance, if you have a large coin and the difference is large enough that it needs many other coins to complete, then, you can compare the two options, where one option involves using a large coin and the other involves using some smaller coins instead. It is also applicable if the problem state could be clearly defined and the solution could be given by a recurrence relation.
Programmers should first precisely define the subproblem when they solve a dynamic programming problem. They have to figure out what the information is to a state, they have to give the base cases, and they have to give a recurrence that tells how the answer depends on the answers to smaller states. They should then decide between a memoization and a tabulation approach, since which one would make it easier to implement and whether all the states need to be computed. Lastly, they should examine the time and space complexity of their solutions to see if they make sense for the size of the data on which they are to be used. Dynamic programming may be inefficient if the number of states is unnecessarily large and/or the recurrence unnecessarily recomputes work that could be simplified. As a result, while it is very strong, it is not always the most optimal solution for all optimization problems. In cases where the correctness of the well-designed greedy algorithm can be proved, it can be much faster.
Time and Space Complexity Comparison
Time complexity describes how the amount of computation grows as the input becomes larger, while space complexity describes how memory requirements grow. Greedy algorithms often have relatively low computational costs because they make one principal choice at each step. Some require sorting before processing the input, resulting in a time complexity of O(n log n), while others can operate in linear time. Dynamic programming typically performs more calculations because it evaluates a collection of subproblems and stores their results. However, its complexity depends on the number of states, the number of choices considered in each state, and the cost of calculating each transition. For example, the standard minimum coin-change algorithm takes O(A × k) time and O(A) space, whereas the standard 0/1 knapsack algorithm takes O(nW) time and can be implemented with O(W) additional space using a one-dimensional table.
These complexity differences explain why a greedy algorithm may be preferable when both approaches guarantee the same result. Nevertheless, programmers should avoid choosing an algorithm based on speed alone. An incorrect greedy solution may run quickly but return a result that fails the problem’s requirements. A dynamic programming algorithm may require additional memory, but that cost can be justified when optimality is essential. It is also important to distinguish between input size and numerical input values when analyzing complexity. For example, the O(nW) running time of the standard 0/1 knapsack algorithm depends on the capacity value W, which may be much larger than the number of bits used to represent it. The most appropriate algorithm is therefore the one that satisfies the correctness requirements while offering acceptable time and memory usage for the expected input.
Common Mistakes When Comparing Greedy Algorithms and Dynamic Programming
One common mistake is assuming that a greedy algorithm always produces an optimal solution because it selects the best-looking option at every step. This assumption ignores the possibility that an early decision may limit later choices and reduce the overall result. The coin-change problem with denominations of 1, 3, and 4 demonstrates this limitation clearly, because selecting the largest coin first can require more coins than selecting smaller denominations. Another mistake is assuming that dynamic programming always evaluates every possible combination individually. In reality, dynamic programming uses stored subproblem results to avoid repeatedly solving the same calculations, which can make it much more efficient than exhaustive search. Programmers should also avoid confusing fractional knapsack with 0/1 knapsack, since the ability to divide items changes whether the value-to-weight greedy rule is guaranteed to work.
A further mistake is overlooking the assumptions required by a particular algorithm. Dijkstra’s algorithm, for example, relies on non-negative edge weights, so it should not be applied without considering whether negative edges are present. Similarly, a dynamic programming recurrence is only correct if its states, transitions, and base cases accurately represent the original problem. Incorrect initialization or an incomplete recurrence can produce a wrong result even when the general technique is appropriate. Students should therefore practice explaining not only how an algorithm works but also why it works, which conditions it requires, and what its complexity means. Comparing different approaches on carefully selected examples can strengthen this understanding. Most importantly, programmers should distinguish between a solution that appears to work on typical inputs and one that has a sound correctness argument for the entire class of valid inputs.
Conclusion
Greedy algorithms and dynamic programming are two fundamental strategies that help programmers solve optimization problems, but they approach decision-making differently. Greedy algorithms select the locally best option at each step and are often efficient when the problem’s structure guarantees that these decisions lead to a globally optimal result. Dynamic programming solves related subproblems, stores their results, and combines them to determine an optimal solution when the problem can be expressed through appropriate states and recurrence relations.
The activity-selection problem and fractional knapsack illustrate situations where greedy strategies work well, while general coin-change problems and 0/1 knapsack demonstrate why comparing alternatives through dynamic programming can be necessary. Shortest-path calculations further show that an algorithm’s suitability depends on its assumptions and the structure of the input. By learning to recognize these conditions, analyze complexity, and justify correctness, computer science students and aspiring programmers can make better algorithmic decisions and develop more reliable software.